MiniNG
Amir’s Mini-NG
Description
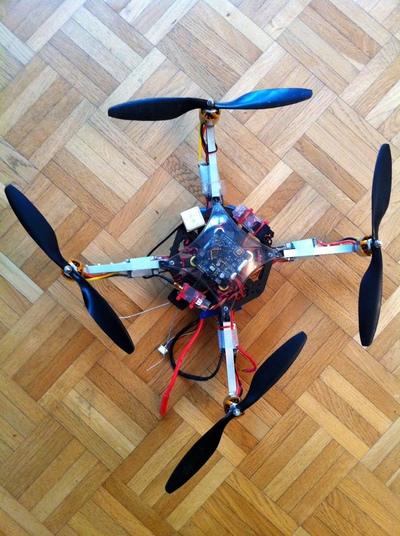
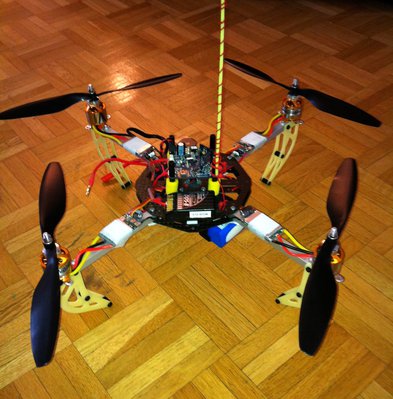
This is a smaller Mini-NG build for fun flying and racing. The copter uses Turnigy 28-30 motors. The frame is built from 1cm aluminium rods.
Specifications
||<tablestyle=“width: 95%">Maidenflight||27.05.2011 || ||HW Revision||HW-0.22-mini-r1|| ||Motors||4x Turnigy 28-30|| ||Controllers||4x TowerPro 2009 25A with Quax’s firmware|| ||Total Weight||920g (with 5000mAh batteries)|| ||Motor Weight||57.9g/motor|| ||Frame Weight||? || ||Frame Type||Alu-Cross 1cm|| ||Frame Span||36cm|| ||Batteries||Turnigy 30C 5000mAh|| ||Receiver||ACT 2.4GHz 4+2XS|| ||GPS||Venus GPS module (10Hz, 14 channel, 32Mbits flash)||
Pictures
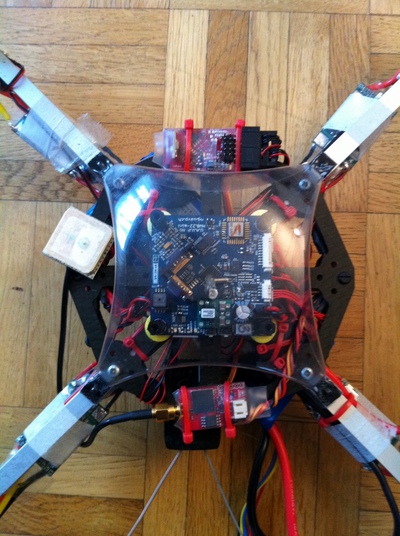
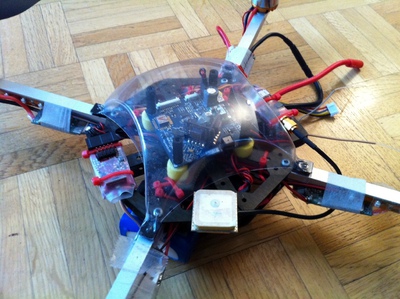
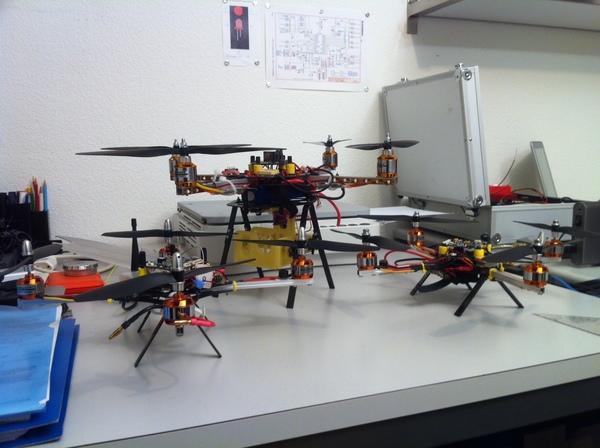
HW-0.22-mini-r1 with GPS and Compass
Older pictures
Movies
First flight with the new GoPro Gimbal:
New GoPro Gimbal:
UAVP-NG at 29c3 - The Chaos Communication Congress in Hamburg
Go to YouTube Site of this video.