Alu44
Amir’s power NG
Description
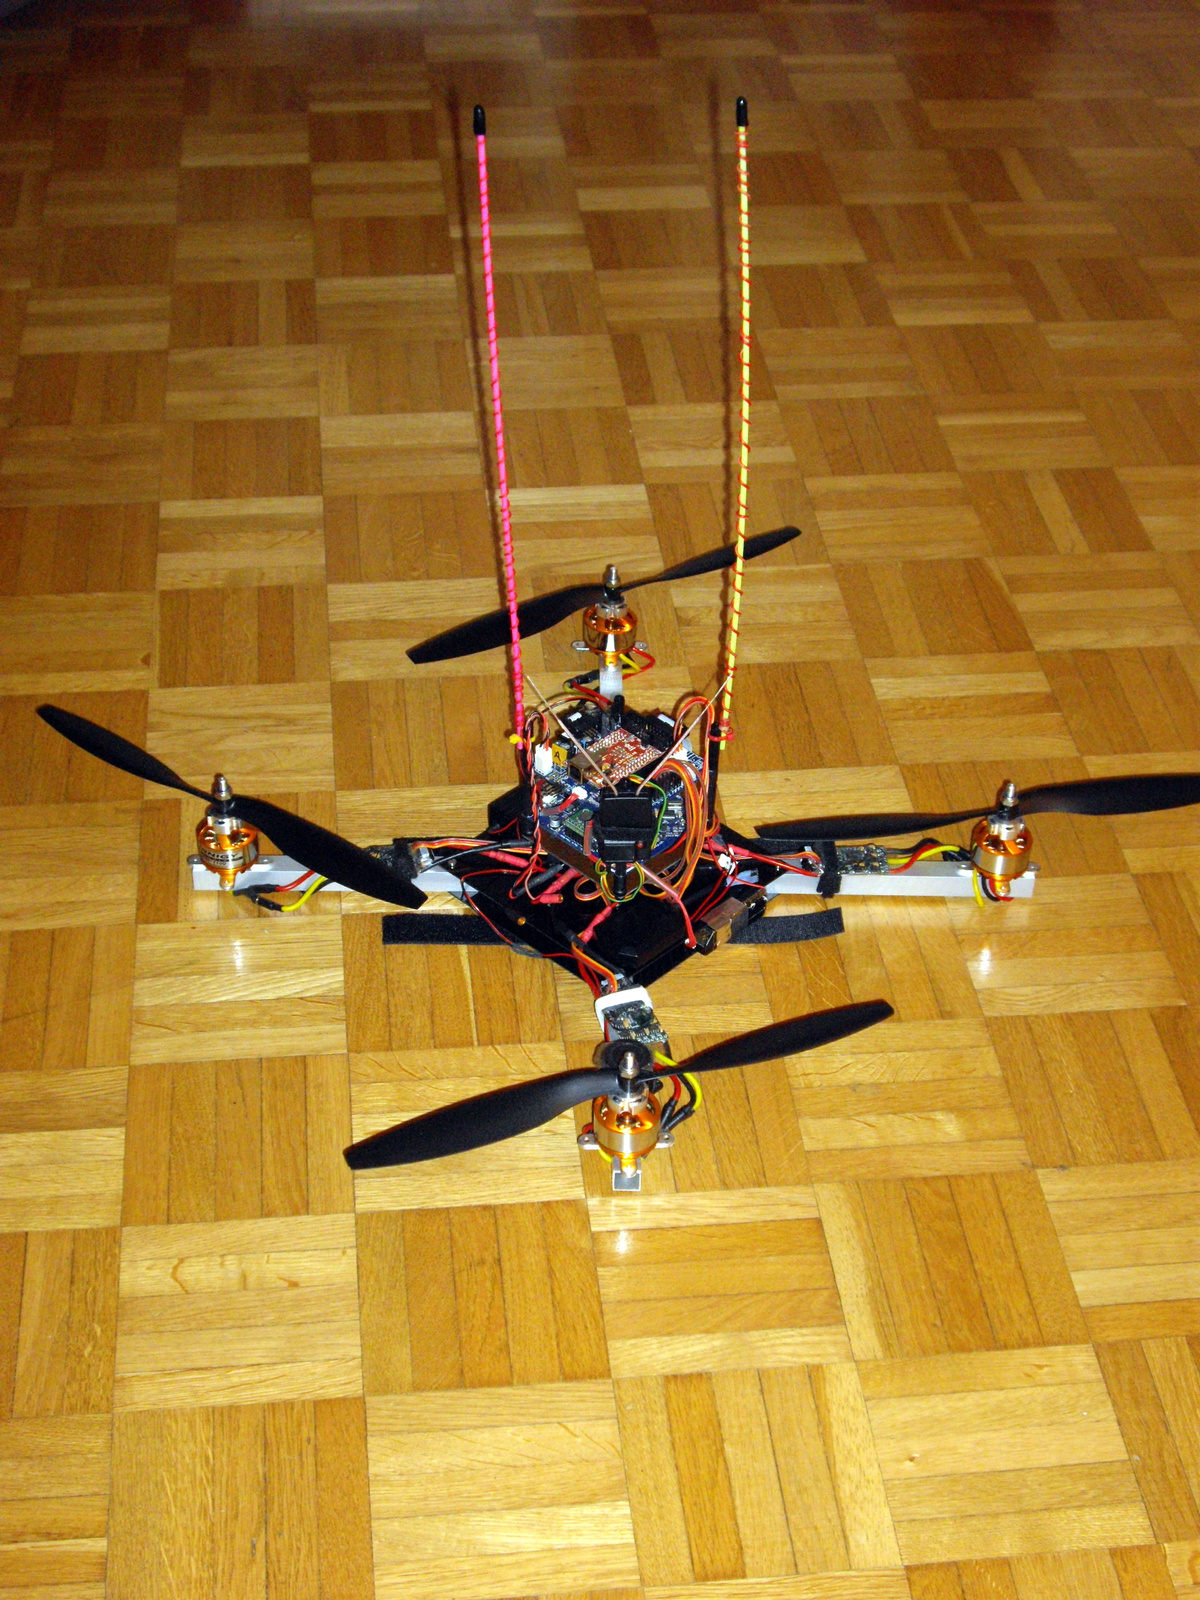
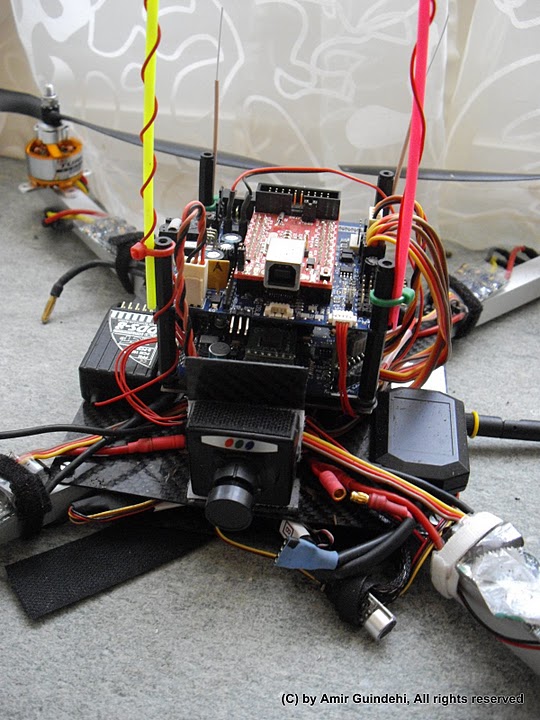
This is a heavy, over-motorized NG built for funflying and racing. The copter uses Turnigy 35-30C motors and the frame is built as stable as possible. We use 1.5cm aluminium rods resulting in a heavier frame than normal.
Specifications
||<tablestyle=“width: 95%">Maidenflight||26.12.2009 || ||HW Revision||HW-0.22|| ||Motors||4x Turnigy 35-30C|| ||Controllers||4x TowerPro 2009 25A with Quax’s firmware|| ||Total Weight||1057g (without batteries)|| ||Motor Weight||78g/motor|| ||Frame Weight||? || ||Frame Type||Alu-Cross 1.5cm|| ||Frame Span||44cm|| ||Batteries||Turnigy 25C 5000mAh|| ||Receivers||1x ACT DDS8 SPCM, 1x ACT 4+2CS 2.4GHz, 1x ACT DSL6 PPM||
Pictures
Movies
Outdoor Maidenflight using the classic controller
Amir’s first sunny flight this year on the 24.03.2010
Go to this video’s Vimeo page
Maidenflight of the new DCM based Controller with Kalman Drift Compensation in SO(3) on the 16.06.2010
This shows the first flight of our new DCM based flight controller with Kalman Drift compensation.
To the Vimeo Site of this Video.
First GPS Position Hold flight on the 24.06.2010
This shows the very first GPS Position Hold flight of our new DCM based flight controller with Kalman Drift compensation in SO(3), the manifold of the special orthogonal group of rotations.
To Vimeo Site of this Video.