FilterConcept
| Development / Controller / amir-ng / | !/FilterConcept |
Controller amir-ng: Filter Concept
The DCM Drift Compensation using three Linear Kalman Filter
This pictures show the data flow inside the DCM based amir-ng Controller using Kalman drift compensation in SO(3). It is essentially a big feedback loop with a non-linear integrator in the middle. The weights select the gains for the linearized equivalent dynamic model.
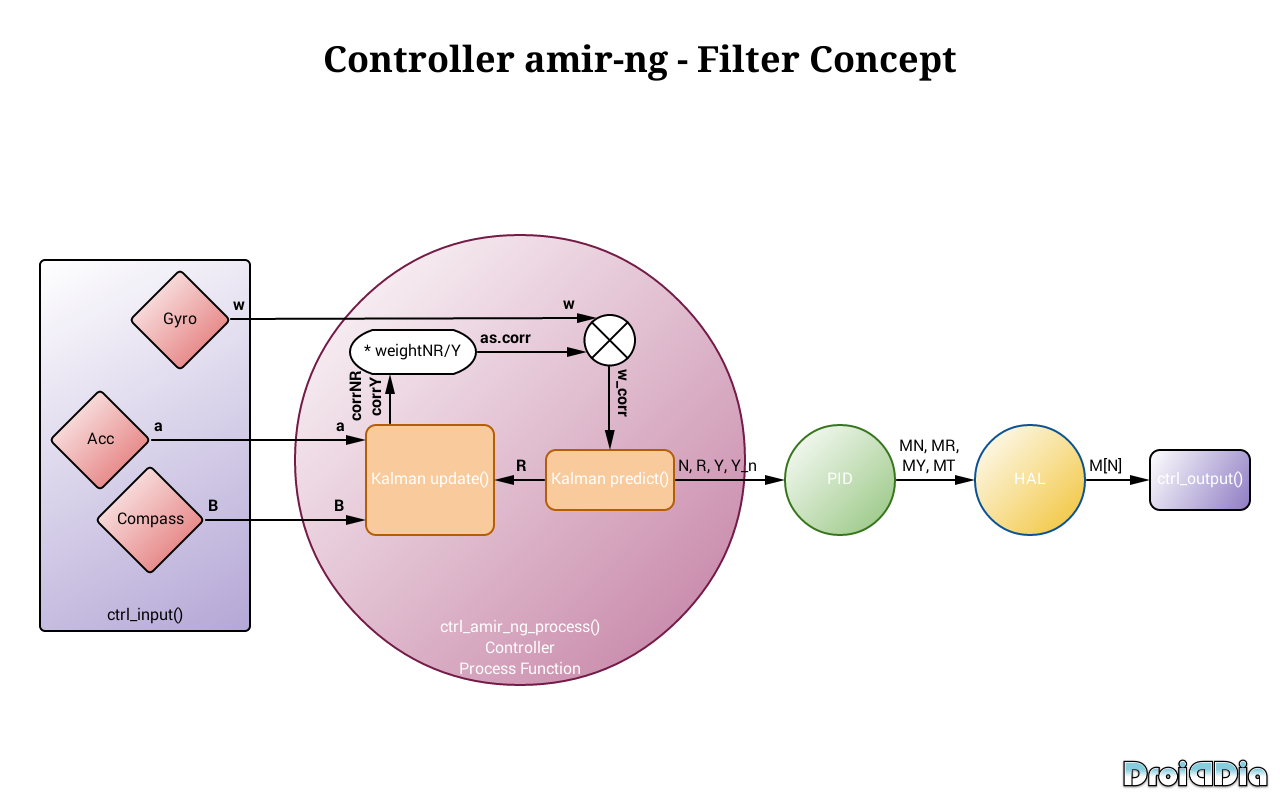
As you can see, the Kalman filter guesses in the Kalman update() function the needed correction for the drift compensation in the Kalman predict() function.