FrontPage
Welcome to the Open Source Next Generation Multicopter
This is a community-driven open source project to build a modern autonomously flying Multicopter. The abbreviation UAVP stands for “Universal Aerial Video Platform”. It is a flying object, ideally suited for making aerial videos and photos (aerial photography), but is also a lot of fun to fly whether indoors or outdoors.
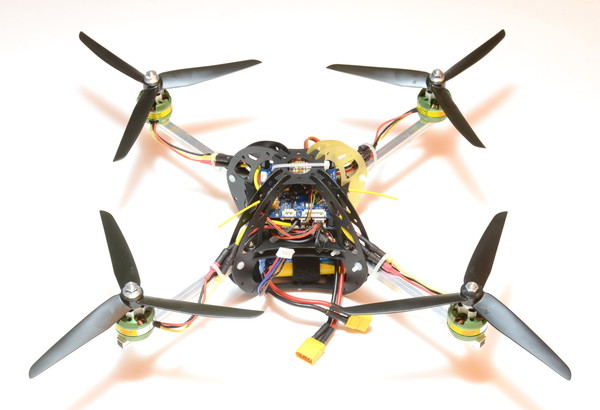
Note:: Please be aware that the UAVP-NG Project and the old UAVP Project are completely separate projects with different developers and different philosophy. The NG has a new, very different software and hardware design!
Note:: MoinMoin Wiki SPAM increased in the last months and we had to close down new account creation to counter that. Currently only NG Developers are able to create new accounts for you! Please join us on IRC Chat and ask for an account if you would like to have write access to this Wiki.
UAVP-NG Hardware 0.30-r1 & 0.30-mini-r1
The new UAVP-NG hardware HW-0.30-r1 and HW-0.30-mini-r1 are finally available for everyone in our non-profit Shop.
Amongst many feature upgrades, the most important difference to the HW0.1x/HW0.2x series is the switch from our trusty old ARM7 based LPC2148 to the more contemporary STM32F4 (Cortex M4) MCU running at 168Mhz with floating point support.
We also worked hard to reorganize our source code base to reflect those changes and improving the portability. We will continue to support both platforms, but the new MCUs will give us the resources to move forward.
The HW0.30 and HW0.30-mini represent the two form-factors we used previously for the HW0.2x and HW0.2x-mini, each with a different focus on features and use cases. For the full-sized HW0.30-r1 we chose a Dual-MCU architecture that offers the possibility to split tasks between an “FC” - MCU handling the flight-critical tasks and a “User” - MCU where for example higher-order control functions or application specific tasks can be implemented. Both MCUs are interconnected via a 32kB dual-port RAM for real-time access. Both form factors feature a lot more interfaces for connectivity compared to the HW0.2x series, all of which will be described in detail here.
UAVP-NG Hardware 0.24-mini
The new UAVP-NG Hardware 0.24-mini consists of one PCB of 5.5cm x 5.5cm in 4 layer called the flight controller board (FC). It contains the 32bit LPC2148 main CPU. The peripherial CPU called RC/Cam-Controller (RCC) is located on a separate small PCB which can be optionally attached to the FC. Additionally it comes with PCBs for the GPS antenna, a JTAG adapter, a push button PCB, an external compass PCB and as mentioned before, the PCB for the RCC.
UAVP Mini-NG HW-0.24-mini PCB fully assembled (top) 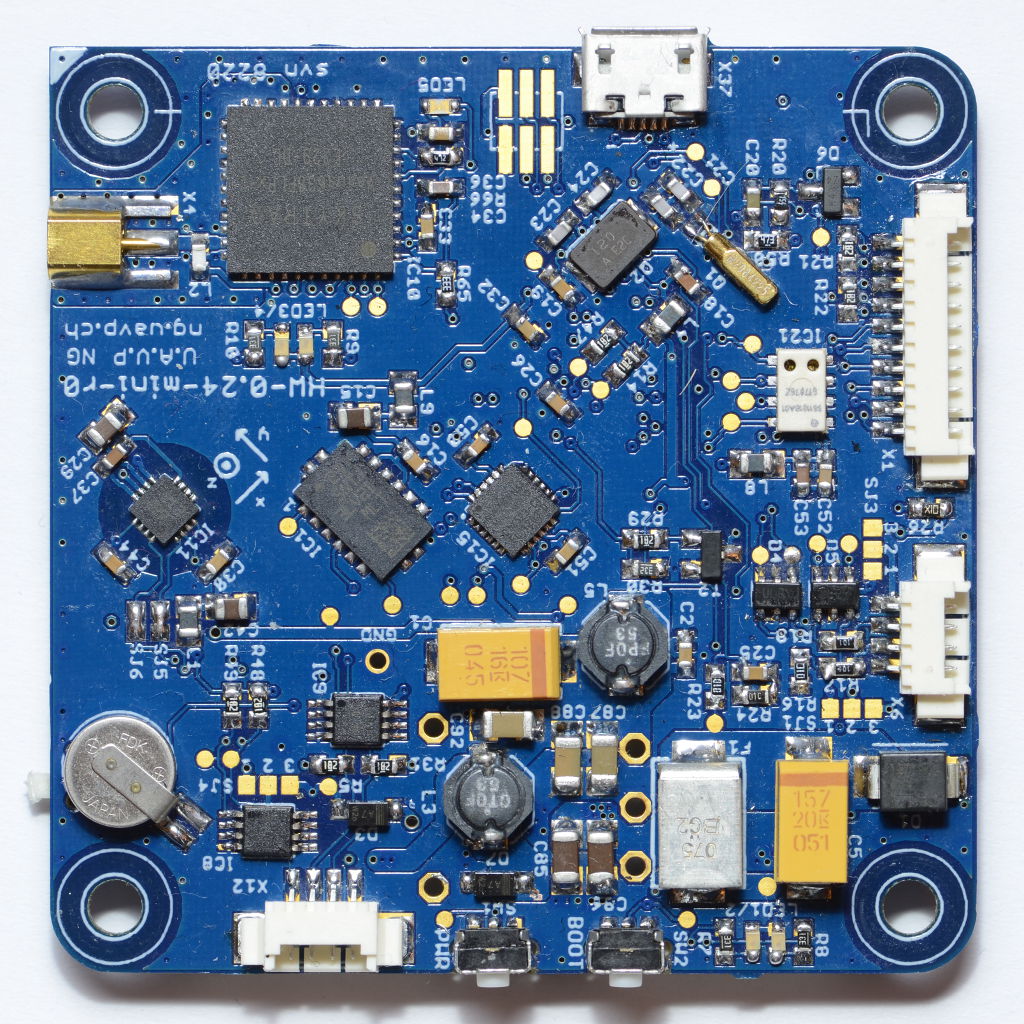 | UAVP Mini-NG HW-0.24-mini PCB fully assembled (bottom) 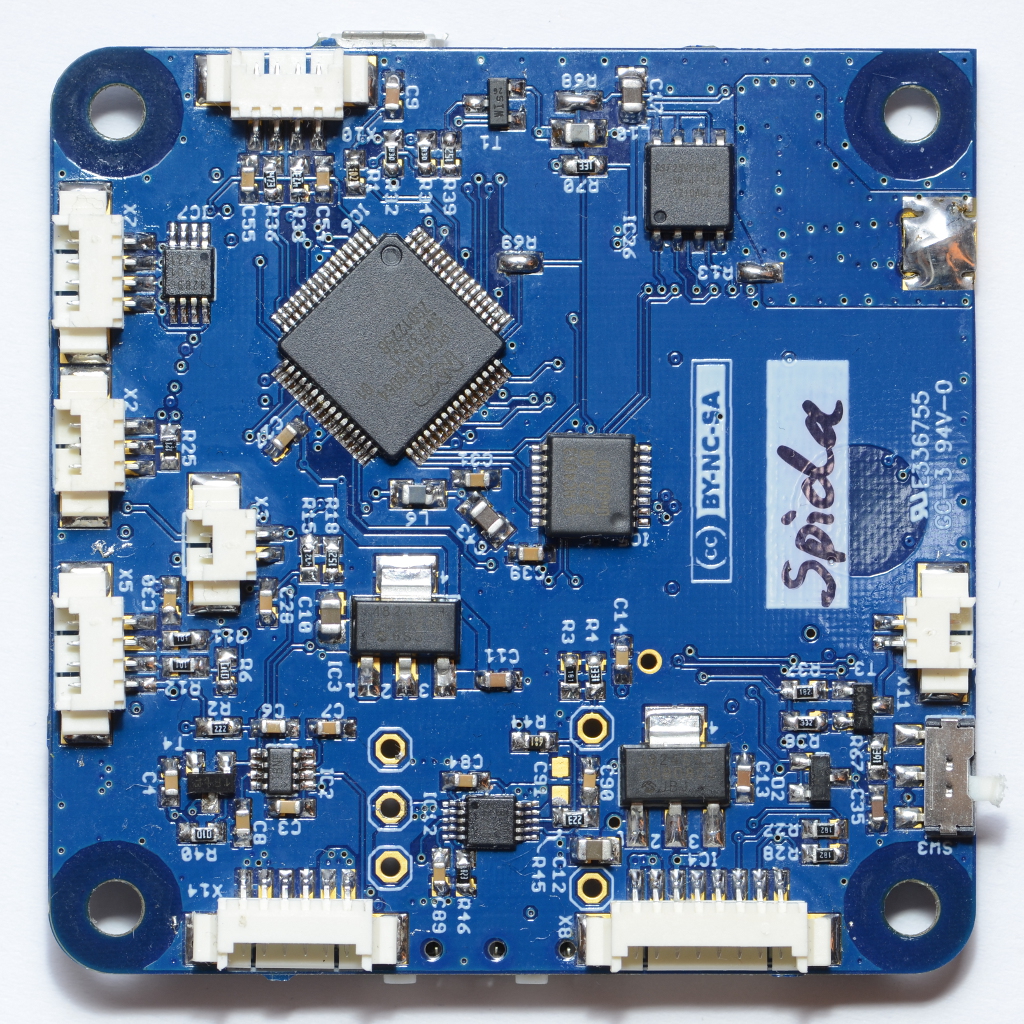 |
This is a feature enhanced miniaturized version of the Hardware 0.22-mini. The LPC2148 is directly soldered to the FC and the FC contains all the digital sensors needed for stabilizing the UAVP-NG and making it easier to fly than other model-helicopters. The flight-controlboard processes the sensor and remote-control data and sends commands to the motors.
The PCB’s are designed to contain any features that anybody could want on a multicopter:
- 1 main CPU (LPC2148) plus 1 peripherial CPUs (Atmel ATmega644P) on a separate PCB
- 3D gyroscope (MPU6000), two 3D accelerometer (MPU6000 + LIS3LV02DQ)
- A barometer (MS5611B)
- A compass (HMC5883L) and a Venus GPS
- Two AD inputs for distance sensors (Sharp IR) and similar
- A sum-signal and 4 serial inputs for several remote-control receivers, GPS and Consoles
- outputs for up to 16 motors and 5 Servos
- much more, see Features
They are optimized for size, weight, features and extensibility, not for easy soldering.
UAVP-NG Quad Brushless Controller NGblc-4mini
The new UAVP-NG Quad Brushless Controller for Mini-NGs and normal NGs consists of one PCB of 80mm x 80mm which can be broken down 12. Next Generation Multicopter Meeting in Heidelberg to 55mm x 55mm for use on Mini-NGs. It supports up to 30A peak per channel.
UAVP NGblc-4mini PCB fully assembled (80mm, top) 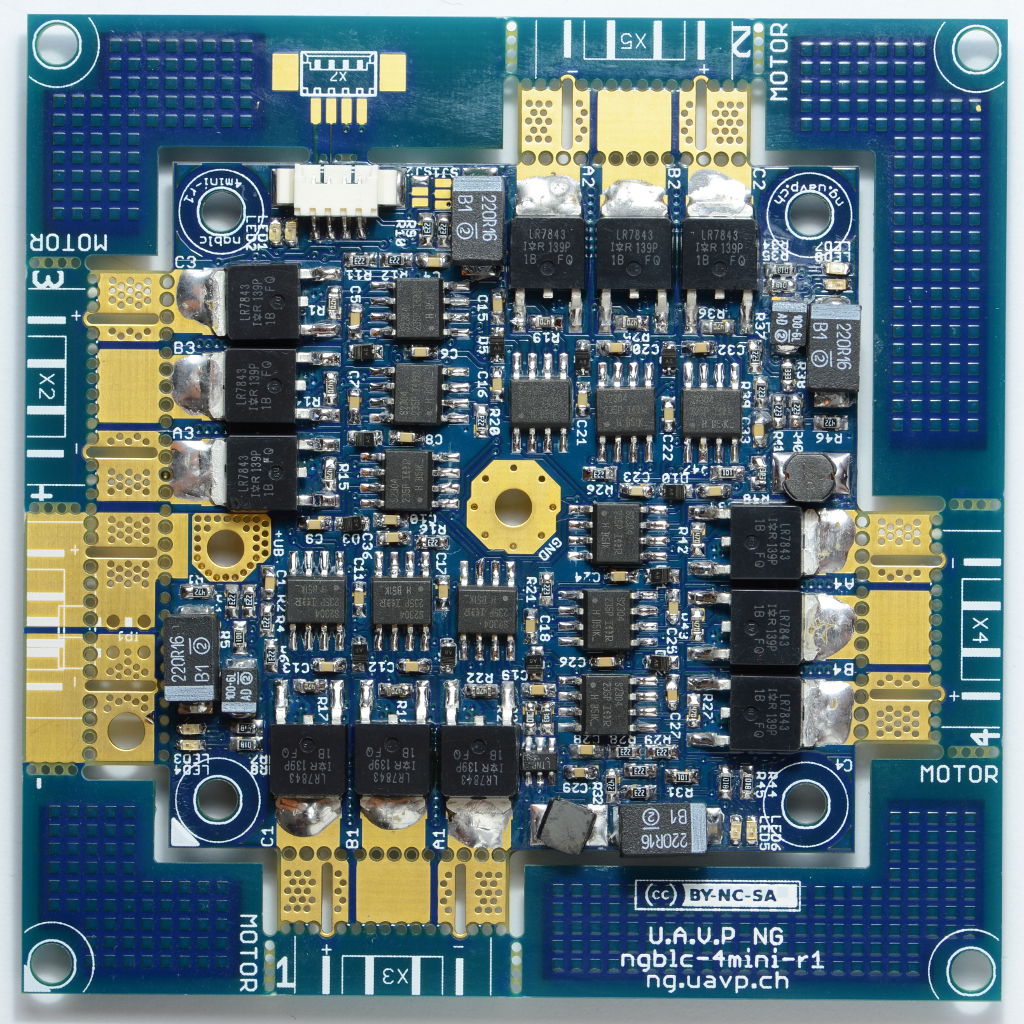 | UAVP NGblc-4mini PCB fully assembled (80mm, bottom) 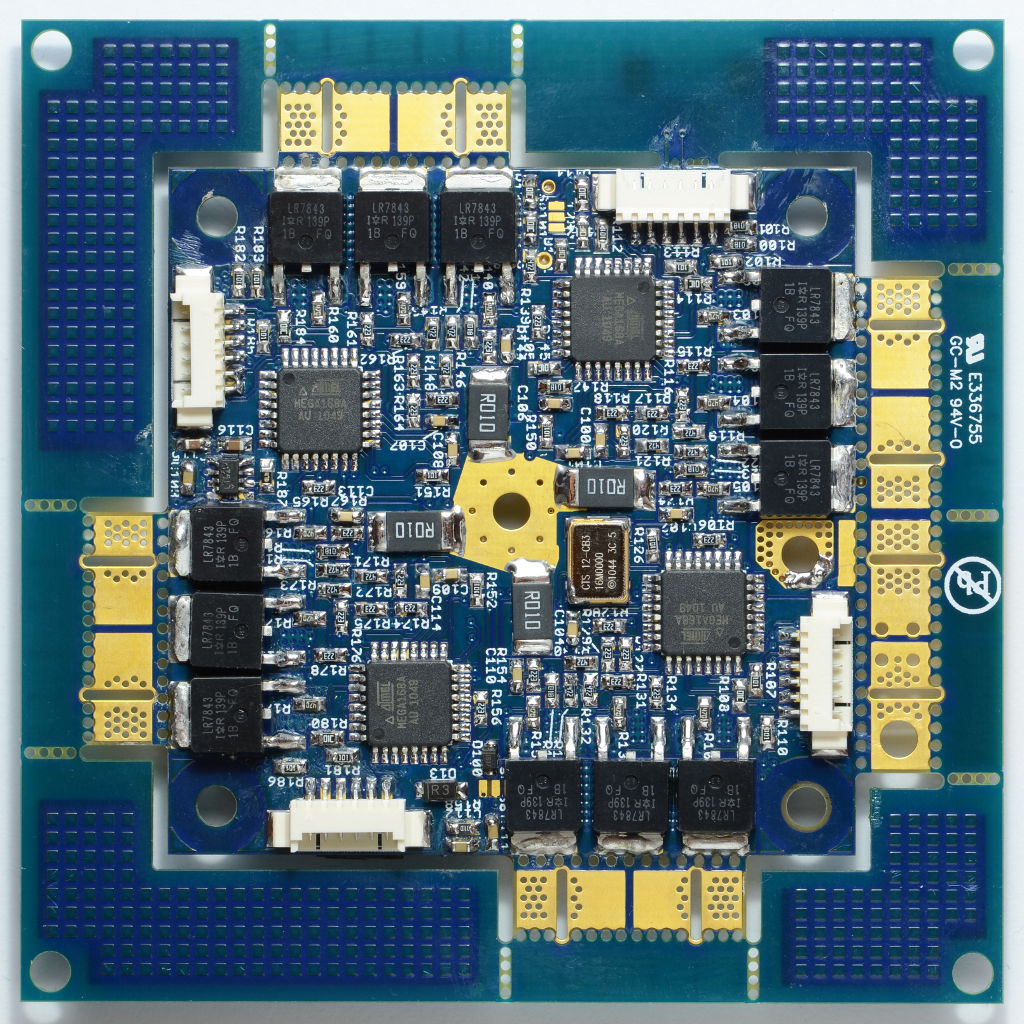 |
UAVP NGblc-4mini PCB fully assembled (55mm, top) 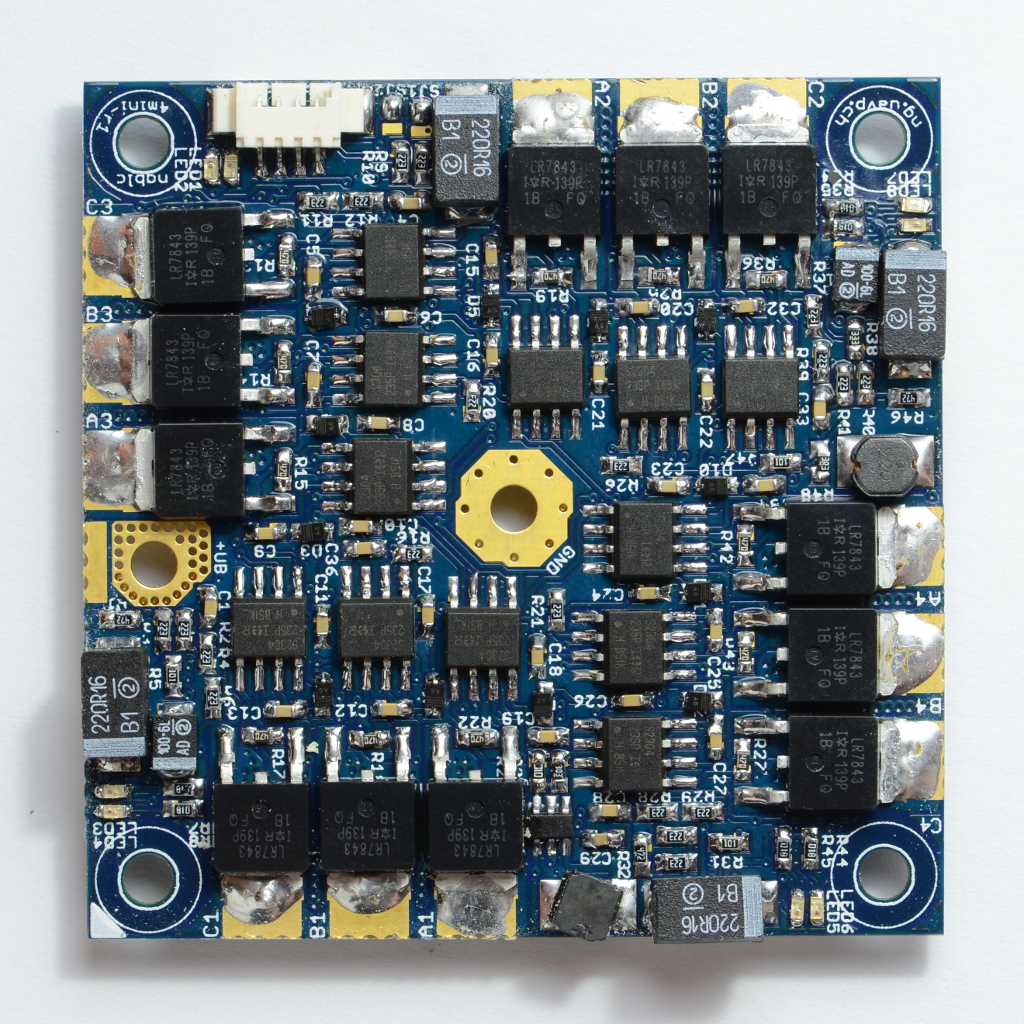 | UAVP NGblc-4mini PCB fully assembled (bottom) 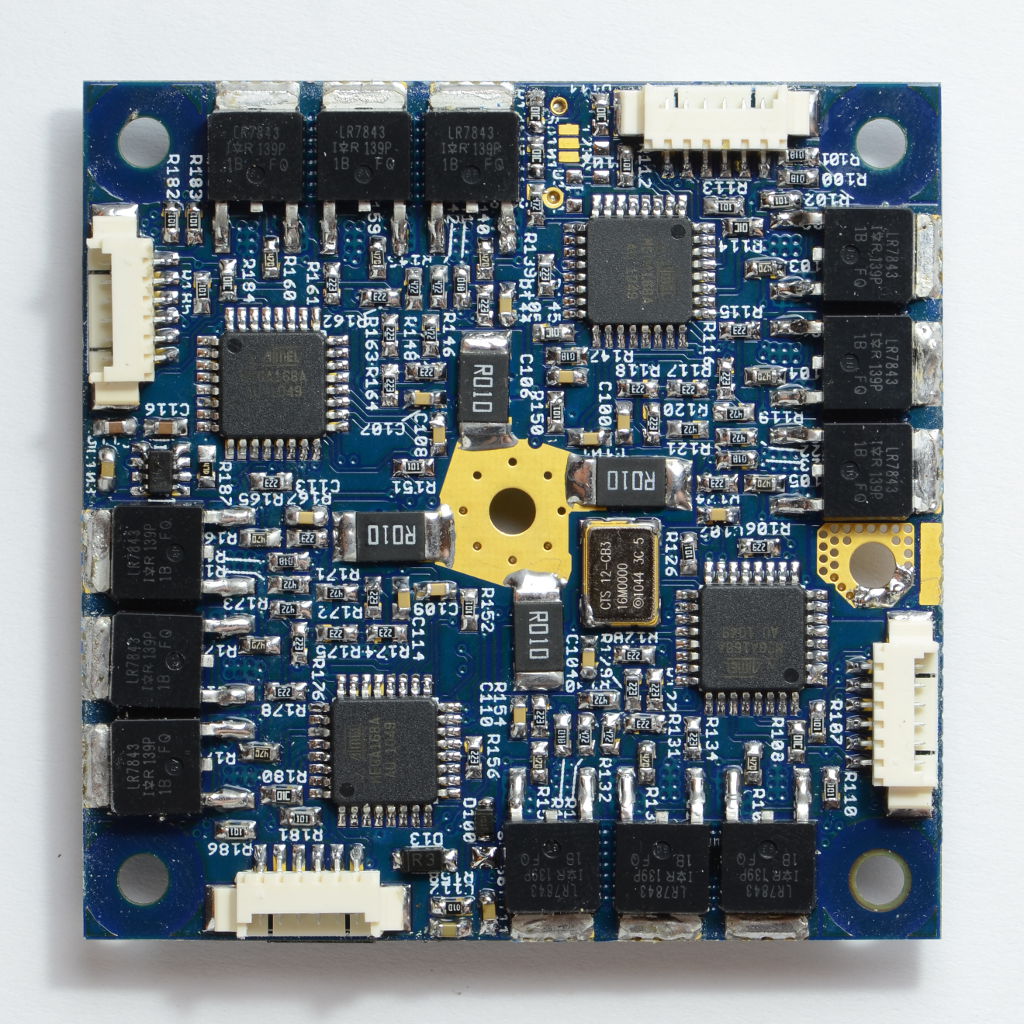 |
UAVP-NG Hardware 0.22-mini
The UAVP-NG Hardware 0.22-mini consists of one PCB of 5.5cm x 5.5cm in 4 layer called the flight controller board (FC). It contains the 32bit LPC2148 main CPU. The peripherial CPU called RC/Cam-Controller (RCC) is located on a separate small PCB which can be optionally attached to the FC. Additionally it comes with PCBs for the 3 gyros, a JTAG adapter and as mentioned before, the PCB for the RCC.
Hardware HW-0.22-mini 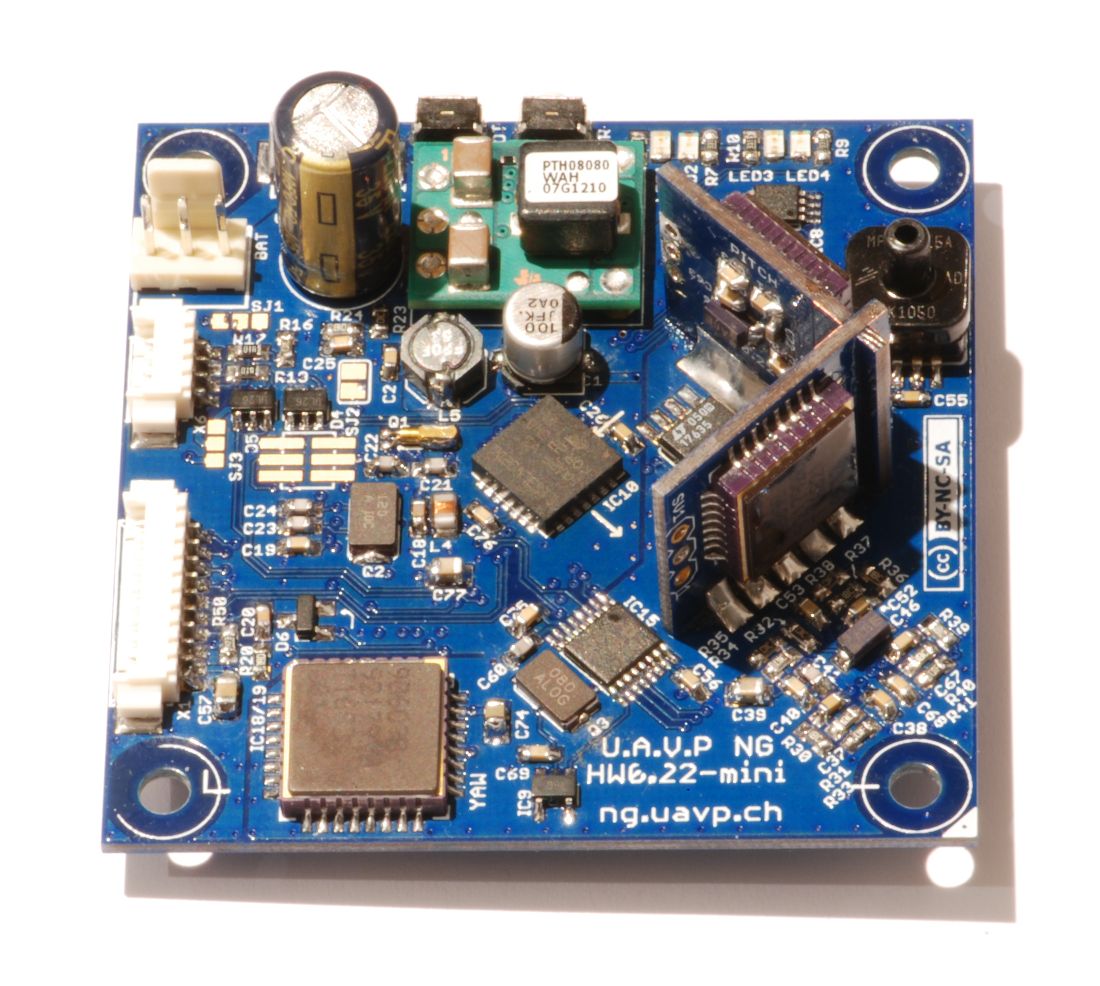 | Size comparision NG (HW-0.22) / Mini-NG (HW-0.22-mini) 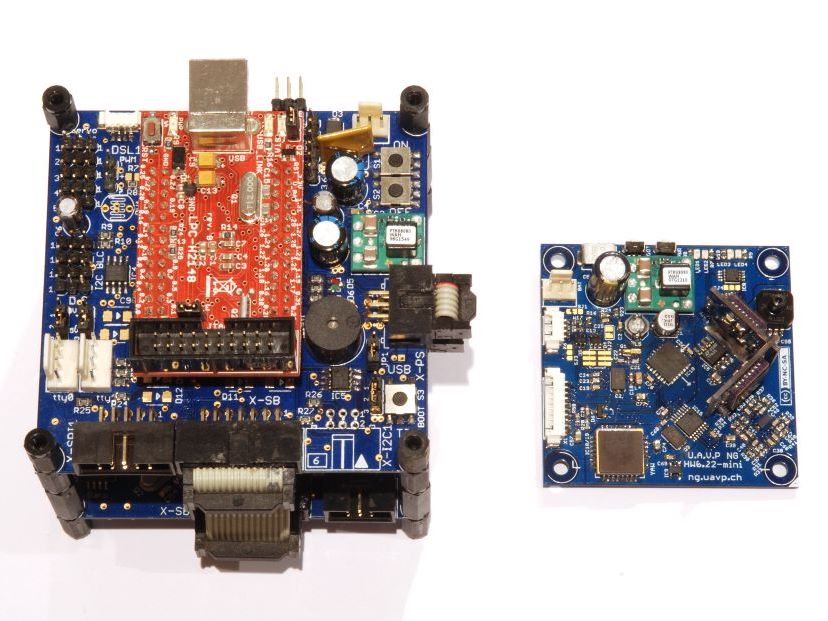 |
This is a feature compatible miniaturized version of the Hardware 0.22. The LPC2148 is directly soldered to the FC and the FC contains all the sensors needed for stabilizing the UAVP-NG and making it easier to fly than other model-helicopters. The flight-controlboard processes the sensor and remote-control data and sends commands to the motors.
The PCB’s are designed to contain any features that anybody could want on a multicopter:
- 1 main CPU (LPC2148) plus 1 peripherial CPUs (Atmel ATmega644P) on a separate PCB
- 3 gyroscopes, a 3D accelerometer, a barometer
- A sum-signal and 4 serial inputs for several remote-control receivers, GPS and Consoles
- outputs for up to 16 motors and 5 Servos
- much more, see Features
They are optimized for size, weight, features and extensibility, not for easy soldering.
UAVP-NG Hardware 0.22
The UAVP-NG Hardware 0.22 consists of two PCBs, the flight-controller board (FC) and the sensor board (SB). Both contain a peripherial CPU called RC-Controller (RCC) and SB-Controller (SBC).
Hardware HW-0.22 (backside) 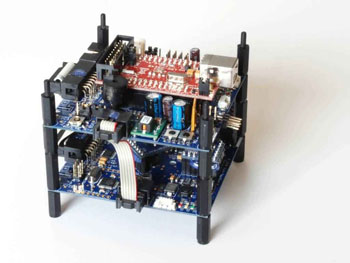 | Hardware HW-0.22 (frontside) 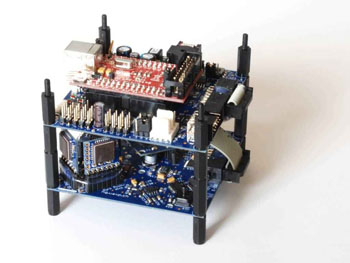 |
The main CPU, an LPC2148, is attached to the Flight-Controller board. The sensor board contains all the sensors needed (and some more…) for stabilizing the UAVP-NG and making it easier to fly than other model-helicopters. The flight-controlboard processes the sensor and remote-control data and sends commands to the motors.
Hardware HW-0.22 Flight Control 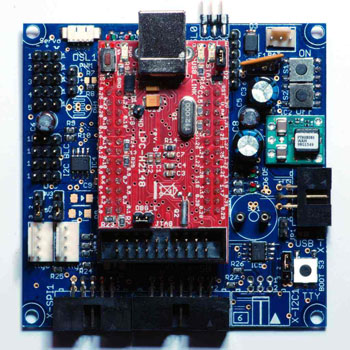 | Hardware HW-0.22 Sensor Board 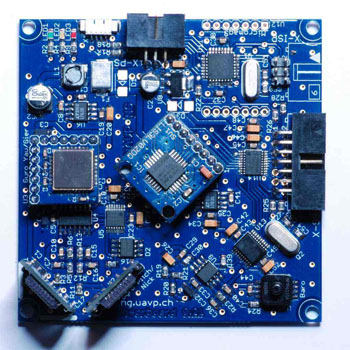 |
The PCB’s are designed to contain any features that anybody could want on a multicopter:
- 1 main CPU (LPC2148, 32bit) plus 2 peripherial CPUs (Atmel ATmega644P and 328P)
- 3 gyroscopes, a 3D accelerometer, a 3D compass, a barometer and thermometer
- A sum-signal and 5 serial inputs for several remote-control receivers, GPS and Consoles
- outputs for up to 16 motors and 5 Servos
- much more, see Features
They are not optimized for size, weight or costs, but for features, extensibility and for easy soldering.
UAVP-NG Copter Software
The UAVP-NG Software, called NGOS, is running on a LPC2148 ARM7 CPU on the flight-control board. It is a modular framework with a Hardware Abstraction Layer (HAL) to use the same on control algorithms on different Hardware (like Quadcopters, Hexacopters, Oktocopters, in different configurations). The Controllers (flight-control algorithms) are modular too, it is even possible to change the used Controller during flight. Customizations can be made through user defined behaviors, where behavior actions can be executed on certain behavior conditions (remote-control action, battery low, remote-control reception lost, whatever).
This modularity enables programmers and non-programmers to work on specific parts of the code without need to understand the complete 80'000 lines of code of the main projects.
If you want to contribute, have a look at the Development Page. You can get access to the source code, which is available under the GPLv3, there.
UAVP-NG Ground Control
There are serveral UAVP-NG Ground Station softwares, which all use a library called libng for communication with NGOS. The library contains several communication APIs of which NGCTRL2 is the newest.
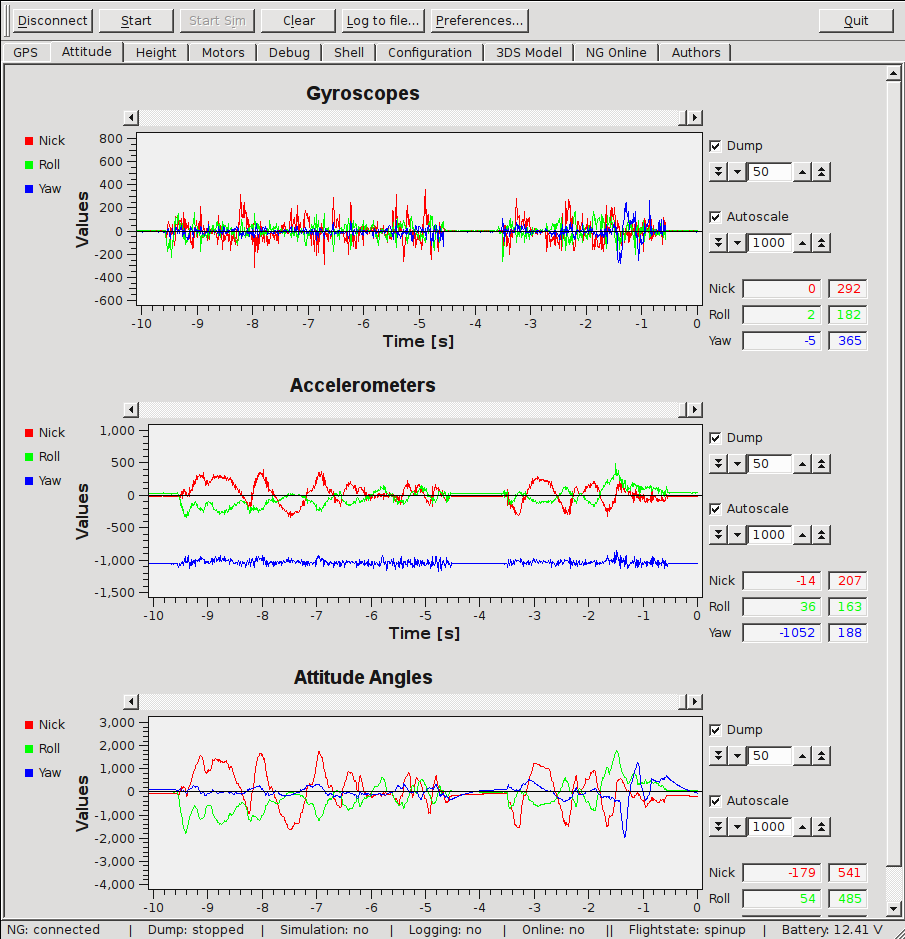
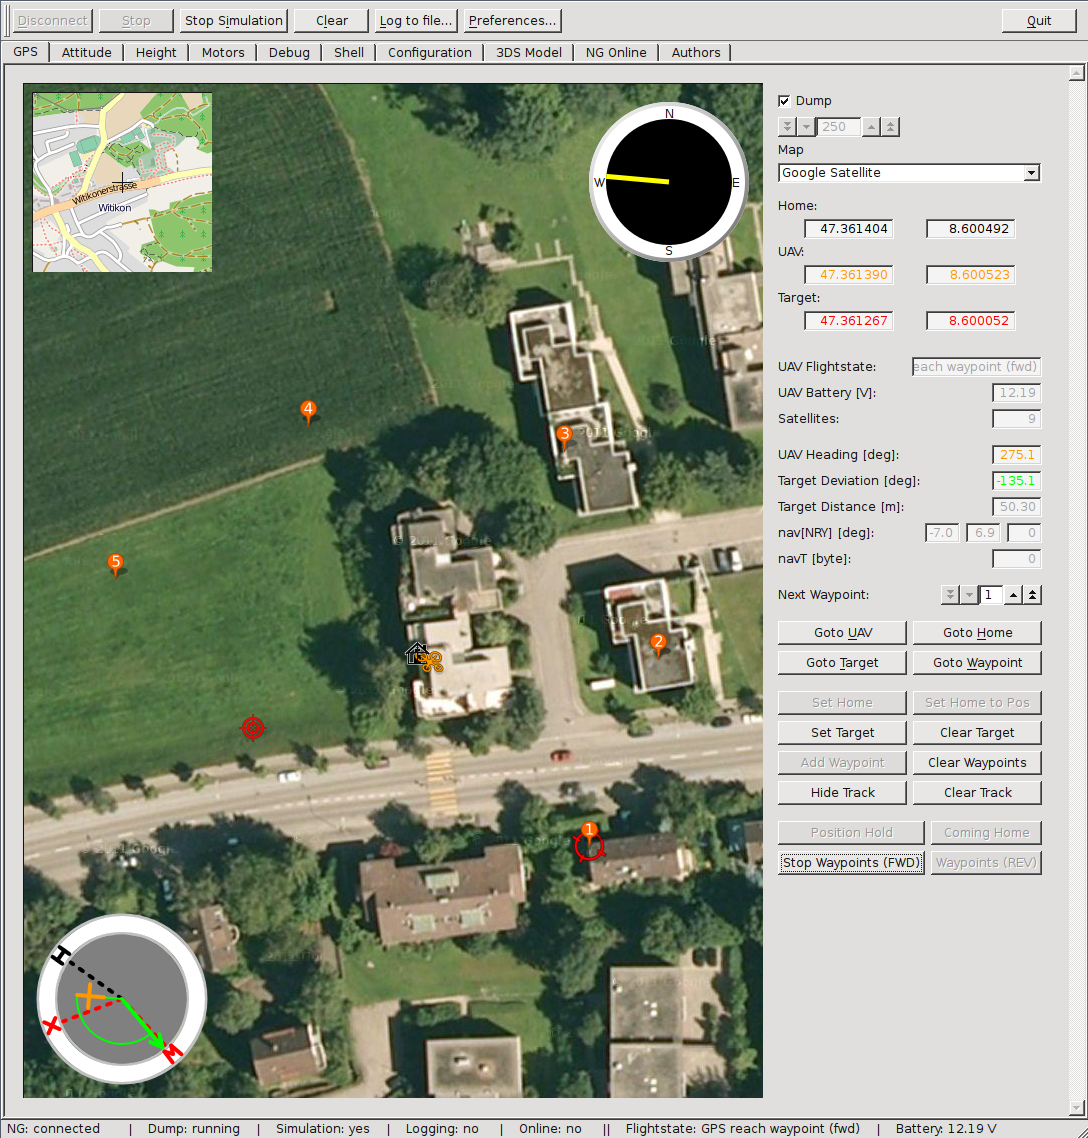
The currently most advanced ground control client is called qngctrl, uses NGCTRL2 and allows visualisation and control of nearly all on-board parameters. The data can be plotted, shown on a map or it can even be used to turn a 3D model.
On the following pictures you see data plots of gyro, acc and angles as well as the NGs position on a Map while GPS and compass have been attached.
 |  |
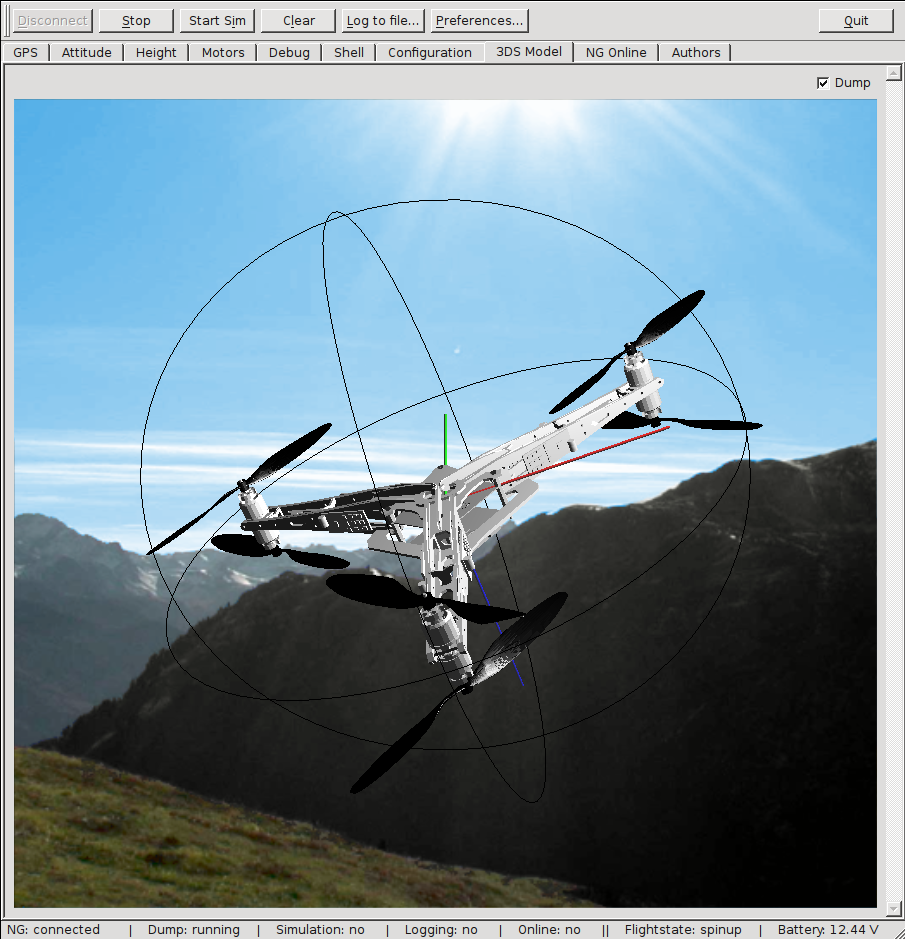
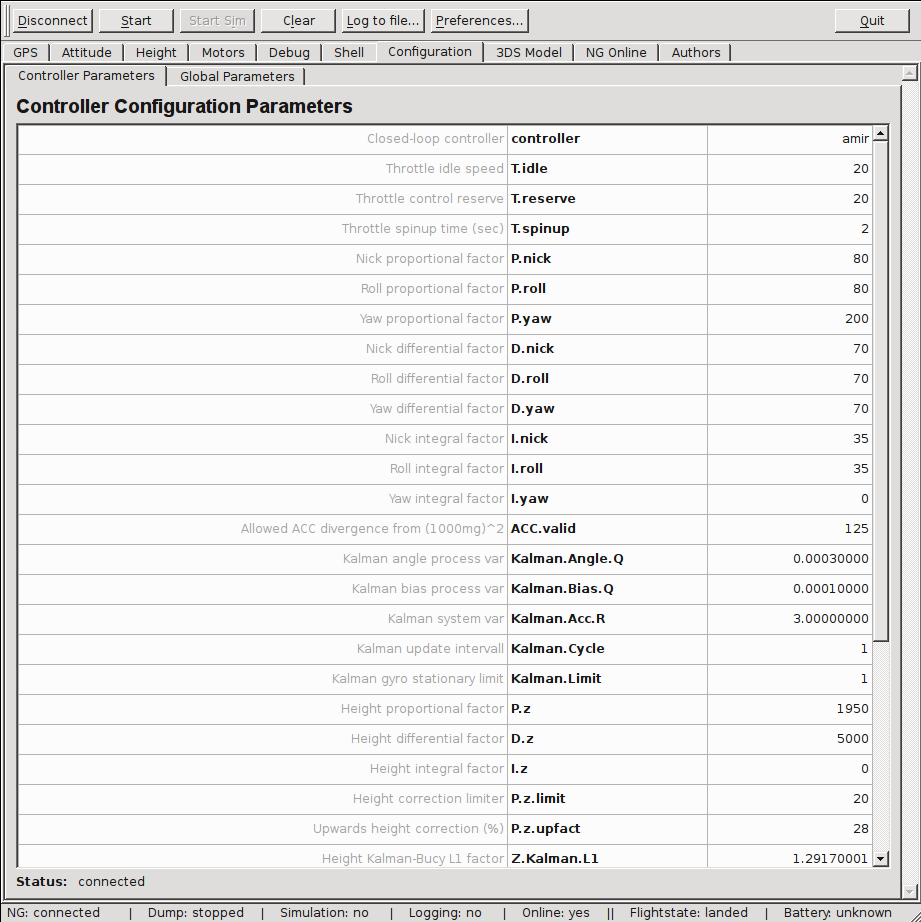
The attitude and orientation of the copter can be visualized using an animaled 3D model and nearly all parameters of the NGOS configuration can be inspected and changed.
 |  |
Get your own
If you want to build a UAVP-NG as well, start with reading trough our Documentation starting at the Requirements page.
You probably should also check our FAQ page which answers common questions.
Note:: This is a community development project and no nice and shiny finished product! This means you should at least have an idea how to solder electronic parts on a board or what a microcontroller is and how to flash it.
Sidenote
Having more and more vistors from China we would like make a political statement here:
. Fight to free Tibet! 自由西藏! Free speech to everyone! Stop Internet censoring now!
We would also like to send our congratulations to Liu Xiaobo, a Chinese dissident who was sentenced to 11 years in prison in December for writing a manifesto calling for freedom of expression and multiparty elections, who won the Nobel Peace Prize Award 2010!
Events
The next events sorted by date:
| 17. UAVP-NG Multicopter Meeting in Heidelberg (Rothenberg), Germany (3 days) | 25.05 - 27.05 |
| 2. UAVP-NG Race Meeting in Zuerich, Switzerland (3 days) | Doodle |
News
The Next Generation Multicopter
The latest News
The latest NG News sorted by date:
| 21.09.2018 | The 19. Multicopter Meeting took place in Freiburg, Germany (3 days) |
| 18.09.2018 | The HW-0.30-mini target was merged into Betaflight another popular flight control software |
| 17.08.2018 | The 18. Multicopter Meeting took place in Zurich, Switzerland (3 days) |
| 25.05.2018 | The 17. Multicopter Meeting took place in Heidelberg, Germany (3 days) |
| 27.12.2017 | The 34. Chaos Communication Congress 34c3 took place in Leipzig, Germany (4 days) |
| 14.10.2017 | The 1. UAVP-NG Race Weekend took place in Zurich, Switzerland (3 days) |
| 04.08.2017 | The SHA 2017 Camp Meeting took place in Scoutinglandgoed, Zeewolde (5 days) |
| 07.07.2017 | The 16. Multicopter Meeting took place in Zurich, Switzerland (3 days) |
| 28.04.2017 | The 15. Multicopter Meeting took place in Heidelberg, Germany (3 days) |
| 27.12.2016 | The 33. Chaos Communication Congress 33c3 took place in Hamburg, Germany (4 days) |
| 09.09.2016 | The 14. Multicopter Meeting took place in Heidelberg, Germany (3 days) |
| 14.07.2016 | The 13. Multicopter Meeting took place in Zurich, Switzerland (4 days) |
| 27.12.2015 | The 32. Chaos Communication Congress 32c3 took place in Hamburg, Germany (4 days) |
| 29.06.2015 | The new HW-0.30-mini-r1 and HW-0.30-r1 boards are available in the Shop |
| 18.06.2015 | The 12. Multicopter Meeting took place in Heidelberg on the 18./19./20./21. June 2015 (4 days) |
| 27.12.2014 | The 31. Chaos Communication Congress 31c3 took place in Hamburg, Germany (4 days) |
| 13.12.2014 | Successful maidenflight of the new HW-0.30-mini-r0 prototype! |
| 23.10.2014 | The first HW-0.30-mini-r0 prototypes for developers arrived. We hope to get them airborne for 31C3. |
| 03.06.2014 | The 11. Multicopter Meeting took place in Zurich, Switzerland (4 days) |
| 04.04.2014 | The new HW-0.30-r1 PCB arrived. |
| 19.01.2014 | Successful maidenflight of the new HW-0.30-r0 prototype! |
| 29.12.2013 | Release of NGOS-0.68 under GPLv3. To contribute, please check the Development page! |
| 27.12.2013 | The 30. Chaos Communication Congress 30c3 took place in Hamburg, Germany (4 days) |
| 24.10.2013 | The first HW-0.30-r0 prototypes for developers arrived. We hope to get them airborne for 30C3. |
| 11.10.2013 | The new Wi.232-NG wireless breakout boards with Picoblade plugs are available in the Shop |
| 26.07.2013 | The 10. Multicopter Meeting took place in Grünstadt, Germany (3 days) |
| 09.05.2013 | The 9. Multicopter Meeting took place in Zuerich, Switzerland (4 days) |
| 13.01.2013 | Release of NGOS-0.67 under GPLv3. To contribute, please check the Development page! |
| 06.01.2013 | Release of NGOS-0.66 under GPLv3. To contribute, please check the Development page! |
| 27.12.2012 | The 29. Chaos Communication Congress 29c3 took place in Hamburg, Germany (4 days) |
| 17.12.2012 | The new HW-0.24-mini-r1 boards and the new NGblc-r2 are available in the Shop |
| 10.11.2012 | Christi succeeds in doing a maidenflight with HW-0.24-mini-r0 |
| 15.09.2012 | The 8. Multicopter Meeting took place in Zuerich, Switzerland (3 days) |
| 25.05.2012 | The 7. Multicopter Meeting took place in Heidelberg on the 25./26./27./28. May 2012 (4 days) |
| 01.05.2012 | The Next Generation Multicopter in the press: Foto Hits 5/2012 - Multikopter im Eigenbau |
| 15.04.2012 | Release of NGOS-0.65 under GPLv3. To contribute, please check the Development page! |
| 30.12.2011 | Our new HW-0.23-mini-r0 with MPU6000, HMC5883L Compass, MBS5607B Altimeter did a successful maidenflight. |
| 21.12.2011 | Release of NGOS-0.64 under GPLv3. To contribute, please check the Development page! |
| 24.11.2011 | Stefan released the current NG-Tools as Debian binary packets and as Subversion packets |
| 10.10.2011 | Release of NGOS-0.63 under GPLv3. To contribute, please check the Development page! |
| 02.10.2011 | Maidenflight of DarkRiver's Mini-NG at 6. Developer Meeting Zürich (CH) |
| 14.08.2011 | Chaos Communication Camp 2011 - UAVP-NG from above |
| 12.08.2011 | The UAVP-NG Project at the Chaos Communication Camp in the german Tagesschau |
| 11.08.2011 | Chaos Communication Camp 2011 - UAVP-NG from the top |
| 11.08.2011 | Chaos Communication Camp 2011 - First on-board video online |
| 28.06.2011 | Taarek flies pirouettes with Amir's Mini-NG using NGOS-0.63 with HW-0.22-mini |
| 04.06.2011 | Release of NGOS-0.62 under GPLv3. To contribute, please check the Development page! |
| 01.06.2011 | A first movie of the 5. NG Developer Meeting in Heidelberg on the 27./28./29. May 2011 |
| 12.05.2011 | Maidenflight of Jan's NG with NGOS-0.61 with HW-0.22 |
| 05.05.2011 | Maidenflight of Ralf's Mini-NG using the new PCBs and NGOS-0.62 with HW-0.22-mini |
| 01.05.2011 | Fnordfunk 062: It flys! - Markus gave an radio interview on RC planes and UAVP quadcopters |
| 21.04.2011 | The UAVP-NG Shop offers the new Mini-NG, called HW-0.22-mini! |
| 20.04.2011 | Maidenflight of Dracos's Mini-NG using the new PCBs and NGOS-0.61 with HW-0.22-mini |
| 19.04.2011 | Maidenflight of Andi's NG using NGOS-0.61 with HW-0.22 |
| 10.02.2011 | New 5.8GHz NG-Video TX/RX PCBs and NG Centerplates are now available in the UAVP-NG Shop |
| 24.01.2011 | Our new Next Generation Multicopter Merchandise Shop opens it's doors! Go and get your NG shirts, cups and stickers! |
| 06.01.2011 | The Next Generation Multicopter in the press: Open Source 03/2010 (the real article) |
| 30.12.2010 | Release of our source code under GPLv3. To contribute, please check the Development page! |
| 27.12.2010 | UAVP-NG on TV: ZDF Heute Journal news coverage of 27c3 and the new Mini-NG prototype |
There is also more Older News.
Other language
Please note that there is a german News page: Neuigkeiten.
Highlights
The Evolution of NGOS
The Evolution of NGOS as seen from the RCS development system:
Gehe zur YouTube Seite dieses Films.
Vertikal launch with higher speed on 02.11.2015
Go to this video’s Vimeo page
Autumn impression on 23.10.2015
Go to this video’s Vimeo page
Flight with gimbal during pretty hard wind on 11.10.2015
Go to this video’s Vimeo page
Mountain Top again
NG at Vodelsang (Bayrischzell)
Gehe zur YouTube Seite dieses Films.
Spring Moves April 2014
Spring Moves
Gehe zur Vimeo Seite dieses Films.
Gipfelstürmer
Gipfelstürmer
Gehe zur YouTube Seite dieses Films.
NG on the Alp
NG on the Alp
Gehe zur YouTube Seite dieses Films.
Autumn Mountains
Autumn Mountains
Gehe zur YouTube Seite dieses Films.
Fun Flying October 2013
NG Tricks
Gehe zur Vimeo Seite dieses Films.
Fun Flying October 2013
NG Cruising
Gehe zur Vimeo Seite dieses Films.
Ranveli, Maldives 13.10.2012
These pictures were made with a Go Pro Hero 2 at on the Ranveli Island on the Maldives. It is a beautiful place for diving and photography!
[Legacy PicasaSlide content unavailable]
Grass Cutting and the village Immighausen from above
Go to this video’s Vimeo page
Flight through two cow sheds
Go to this video’s Vimeo page
FPV flight around a straw stack
Go to this video’s Vimeo page
Flight through the ruin of monastry Schaaken
Go to this video’s Vimeo page
DarkRiver flies some NG-UAVP Loopings with the new heading hold algorithm on the 04.08.2012
The new heading hold algorithm will be in release 0.66.
To Vimeo Site of this Video.
Ralf’s aerial movie: NG-UAVP from above
Go to YouTube Site of this video.
Taarek’s first pirouettes on the 28.06.2011
Go to this video’s Vimeo page
Robert’s Footage of the 5. NG Developer Meeting in Heidelberg on the 27th / 28th / 29th of May 2011
Go to Vimeo Site of this video.
5. NG Developer Meeting in Heidelberg on the 27th / 28th / 29th of May 2011
Go to Vimeo Site of this video.
UAVP-NG at 27c3, the 27th Chaos Computer Club Congress in Berlin on the 27.12.2010
The quadcopter visible at the beginning of the movie is a prototype of our new UAVP-NG Mini! It did it’s maidenflight at 27c3.
Go to YouTube Site of this video.
Ygramul’s NG FPV impressions on the 22.08.2010
Thrust/Weight is still at about 2/1. Used amir-ng controller and quadX hal.
For more information see my thread in the NG Forum.
Go to Vimeo Site of this video.
Other language
Please note that there is a german Frontpage: StartSeite.
BitCoin Donations
If you would like to donate BitCoins to the project use the following address to send your BTC to:
1HQMMR98ofevuE4U5dBNPPDxJPEoujhtau